Title:
Photogrammetry-Based Localization and Trajectory Optimization for Autonomous Aerial Vehicle Landing with Single Camera System
Author:
Supervisor:
Department:
Electrical & Electronics Engineering
Year:
2026
URL:
Abstract:
The rapid expansion of Autonomous Aerial Vehicles (AAVs) in domains such as disaster response, urban logistics, and environmental monitoring has amplified the demand for advanced landing systems capab...
View more
Multimedia Content:
01
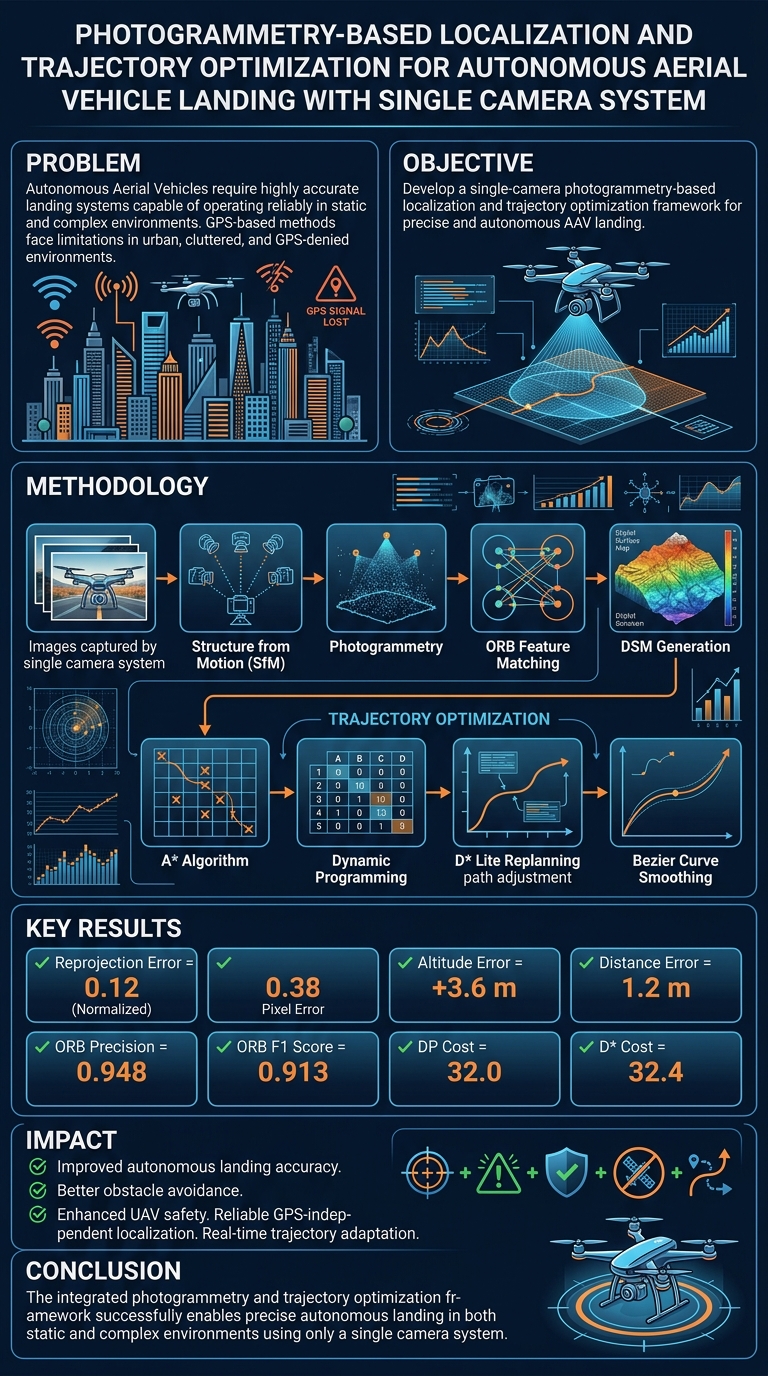
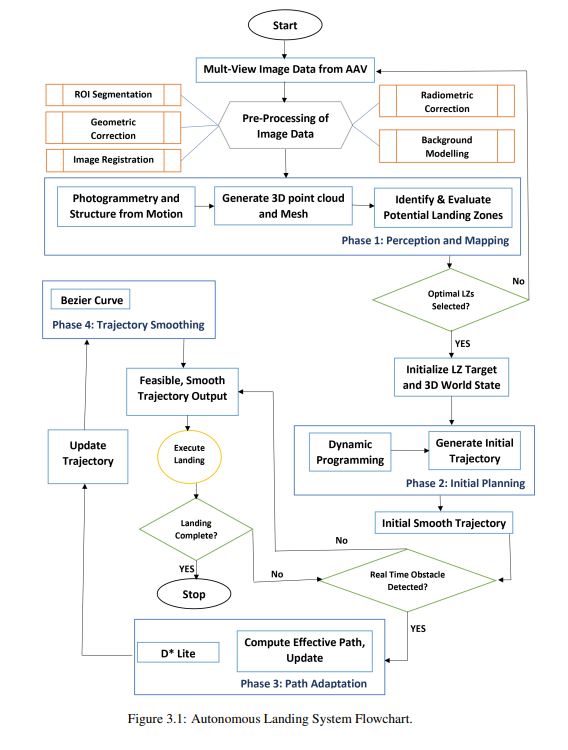
Methodology
1. Structure from Motion (SfM)
Structure from Motion (SfM) was employed as the core photogrammetric technique to reconstruct three-dimensional terrain information from multiple aerial images acquir...
View more
02
Citation Analysis
1. Drones
Scope: UAV systems, autonomous navigation, aerial robotics, drone applications, and autonomous landing technologies.
Relevance: Directly aligned with autonomous aerial vehicle landing, c...
View more
03
Impact
1. Technical Impact
This research introduces a complete photogrammetry-based localization and trajectory optimization framework for Autonomous Aerial Vehicle (AAV) landing using only a single camer...
View more
04
Benefits to Society
1. Environmental Benefits
The proposed vision-based landing framework enables UAV operations without requiring extensive ground infrastructure or heavy sensing equipment. More efficient UAV deploym...
View more
05
Applications
1. Autonomous Drone Landing Systems
Benefit: Improves landing accuracy and reduces operator dependency.
Implementation: The framework can be integrated directly into UAV onboard vision systems to ...
View more
06
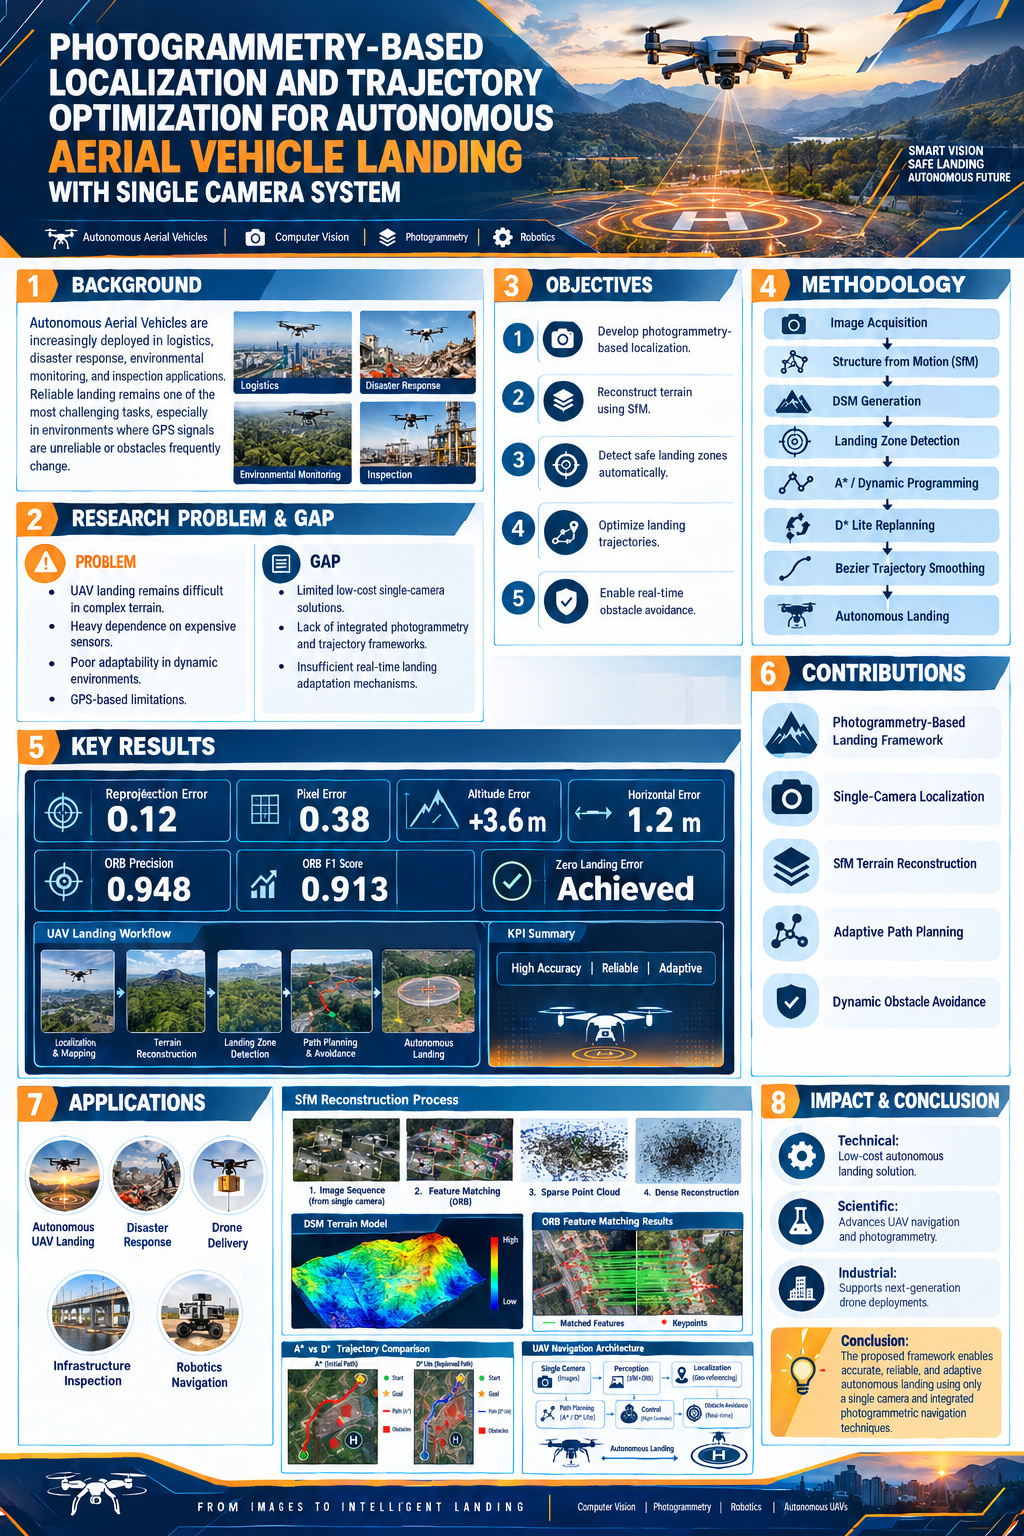
Infographic
Summary of this Thesis
07
Patents / Products
Product Name:
Photogrammetry-Based Localization and Trajectory Optimization Framework for Autonomous Aerial Vehicle Landing
Significance:
The framework provides a complete autonomous landing solu...
View more
08
Experts
1. AP. Dr. Vijanth Sagayan Asirvadam
Institution: Universiti Teknologi PETRONAS (UTP), Malaysia
Contribution: Main supervisor responsible for the development of the autonomous landing framework.
...
View more