Title:
Deep Supervised Light Weight Networks for Visual Odometry Estimation
Author:
Supervisor:
AP Ts Ir Dr Irraivan Elamvazuthi
Dr Lila Iznita Izhar
Department:
Civil & Environmental Engineering
Year:
2024
URL:
Abstract:
Visual odometry involves the computation of an autonomous agent's pose by analyzing images. Utilizing deep learning to estimate visual odometry enhances robustness against noise. Training neural netwo...
View more
Multimedia Content:
01
Methodology
1. Research Design
The study follows an experimental research design that integrates supervised deep learning techniques with lightweight convolutional neural networks (CNNs) to improve visual odomet...
View more
02
Citation Analysis
1. Sensors (MDPI)
Scope: Covers sensor technologies, computer vision, robotics, and autonomous systems.
Relevance: Your work on lightweight deep learning networks for visual odometry fits well und...
View more
03
Impact
1. Societal Impact
• Advancement in Autonomous Mobility:
The thesis contributes to safer and more efficient autonomous vehicles by improving how visual odometry systems estimate camera motion in r...
View more
04
Benefits to Society
1. Societal Benefits
Safer Autonomous Systems:
The proposed lightweight visual odometry networks enhance the accuracy and stability of autonomous vehicles and drones, leading to safer navigation i...
View more
05
Applications
1. Autonomous Vehicles and Driver Assistance Systems
Application: Real-time visual odometry for localization and navigation.
Use Case: Self-driving cars and advanced driver-assistance systems (ADA...
View more
06
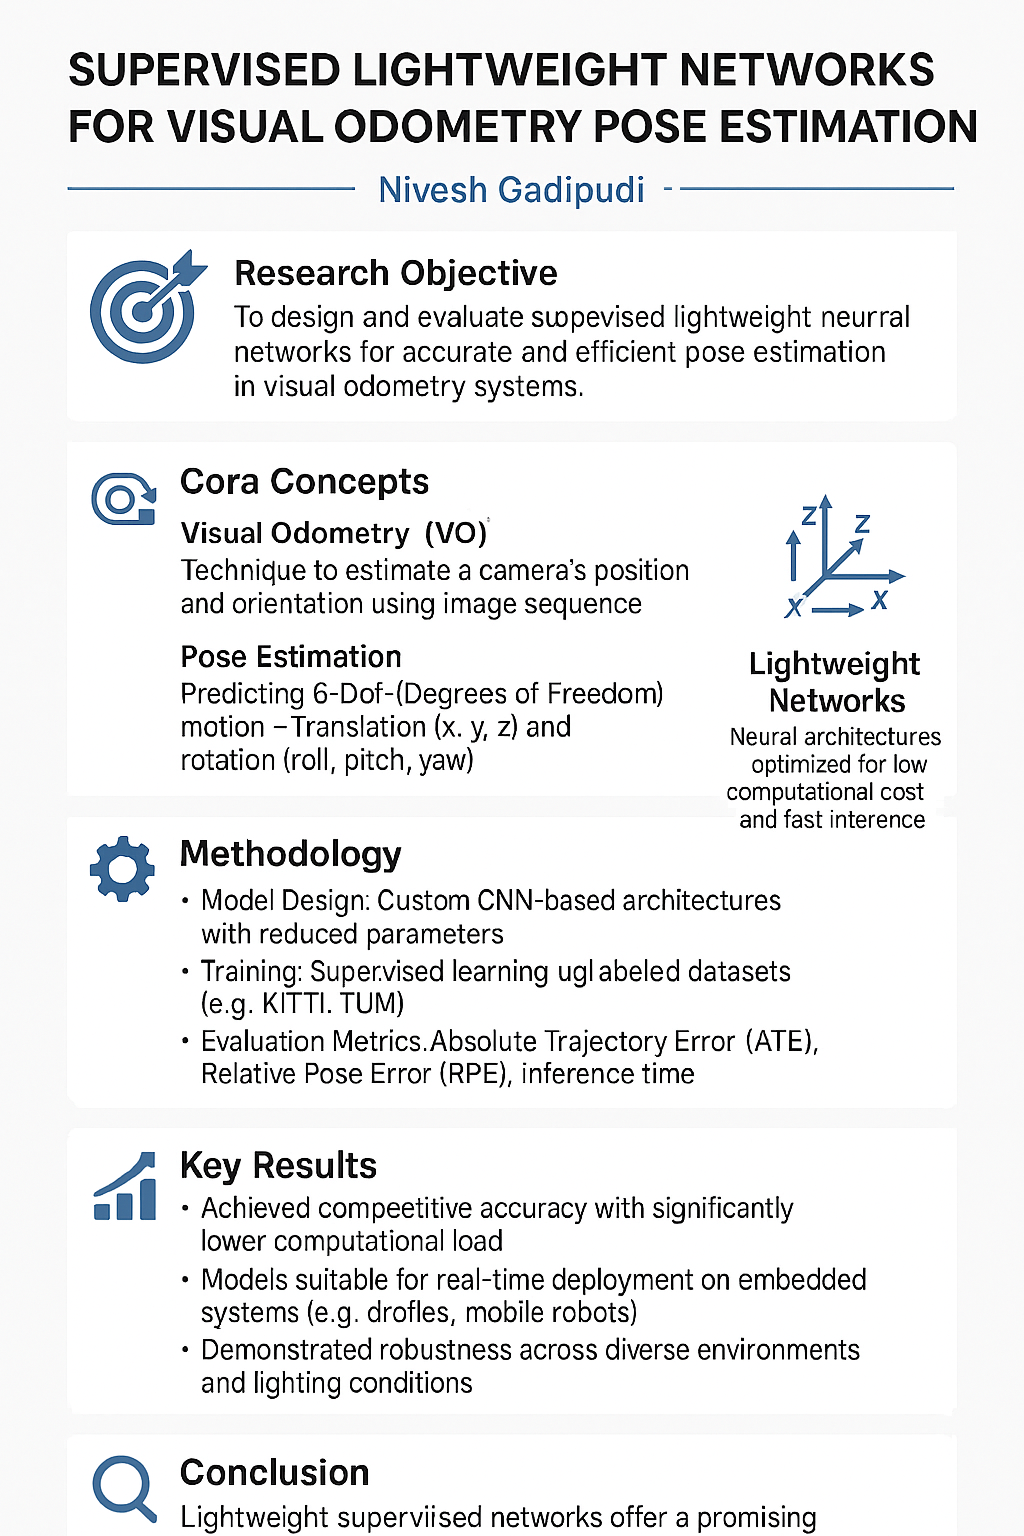
Infographic
Summary of this research
07
Patents / Products
1. Lightweight Visual Odometry Neural Engine
Product Type: Deep learning software module or embedded AI chip architecture
Use Case: Integrate into autonomous vehicles, drones, or robots to perform...
View more
08
Experts
1. Raúl Mur-Artal
Institution: Technical University of Munich (TUM), Germany
Contribution: Creator of ORB-SLAM and co-developer of ORB-SLAM2, two of the most influential open-source visual odometr...
View more